Who Invented Driverless Cars? A History of Many Hands
No single person invented driverless cars. The work grew from early radio-control experiments in the 20th century, 1960s automated-guidance research, and 1980s and 1990s road tests that turned lab systems into prototype self-driving vehicles. If you stop at one name, you miss the sensors, software, test cars, and funding that came from different places. Here is the timeline of the earliest milestones and the people and institutions that mattered most.
Ernst Dickmanns and the 1986 Mercedes testbed
The short answer is nobody alone. Ernst Dickmanns is one of the earliest pioneers worth naming, but the history belongs to a chain of researchers, university teams, corporate backers, and national and European programs that moved autonomy from theory to public roads.
“Invented” needs care here. A lab test, a skidpan run, a motorway demonstration, and a long-distance drive are different achievements, even when they use the same vehicle family and the same research group. Credit shifts with each step.
The pre-1986 roots of autonomy
Before Dickmanns’ road tests, autonomy already had a technical base. Control systems research, robotics, and machine vision had taught engineers how to sense a path, estimate motion, and issue steering commands without a human hand on the wheel.
Dickmanns did not start from zero. He built on feedback control, vehicle guidance, and computer vision work that had matured for years, then pushed it into faster, messier, real-world driving conditions.
Where Ernst Dickmanns fits in the timeline
Dickmanns, a German scientist and aerospace engineer, began testbed work in 1986 with a Mercedes van. That van carried computers, cameras, and sensors, and the early tests made it an early demonstration of a road vehicle steering itself under machine control.
The vehicle is often tied to the first autonomous vehicle on a skidpan, which matters because a skidpan is controlled space, not open traffic. It was an early autonomous test vehicle, not a production-ready system.
Ernst Dickmanns and the 1986 mercedes van
What did Dickmanns build in 1986? A Mercedes van turned into a research platform. It carried computers, cameras, and sensors, and university tests let the team work on perception, control, and vehicle guidance together.
The point was not styling or commercial readiness. The point was to prove that the software and hardware could keep a vehicle aligned and moving without continuous human steering input.
How cameras, sensors, and computers guided the van
The setup depended on the vehicle reading its environment, then sending that information to onboard computers that decided what to do next. That meant the system had to detect lane position or track cues, interpret them quickly, and turn the wheels with enough precision to stay on course.
Picture a 1986 test vehicle following a marked path in a university lot. If the camera read the markings poorly or the control loop lagged, the van drifted. That failure mode explains why early autonomy depended as much on computing speed and sensor quality as on mechanical steering.
Driverless cars history timeline
The table below separates the milestones that often get blurred together. Each step involved a different setting, a different risk level, and a different kind of public proof.
| Milestone | Who was involved | Where it happened | Why it mattered |
|---|---|---|---|
| First lab test | Ernst Dickmanns and his university research team | University premises in 1986 | Showed that a Mercedes van with computers, cameras, and sensors could be guided automatically in a controlled research setting. |
| First road test | Dickmanns’ team | Empty Bavarian autobahn in 1987 | Moved the work out of the lab and onto a real highway, reaching about 90 kilometers per hour. |
| First public motorway demo | PROMETHEUS project engineers, with Dickmanns’ research in the mix | France’s Autoroute 1 in October 1994 | Put autonomous driving in public motorway traffic, with engineers still sitting in the front seat. |
| First long-distance drive | The same broader research effort | From Bavaria to Denmark | Showed that the re-engineered car could cover more than 1,700 kilometers and exceed 175 kilometers per hour. |
First road test: the Bavarian autobahn
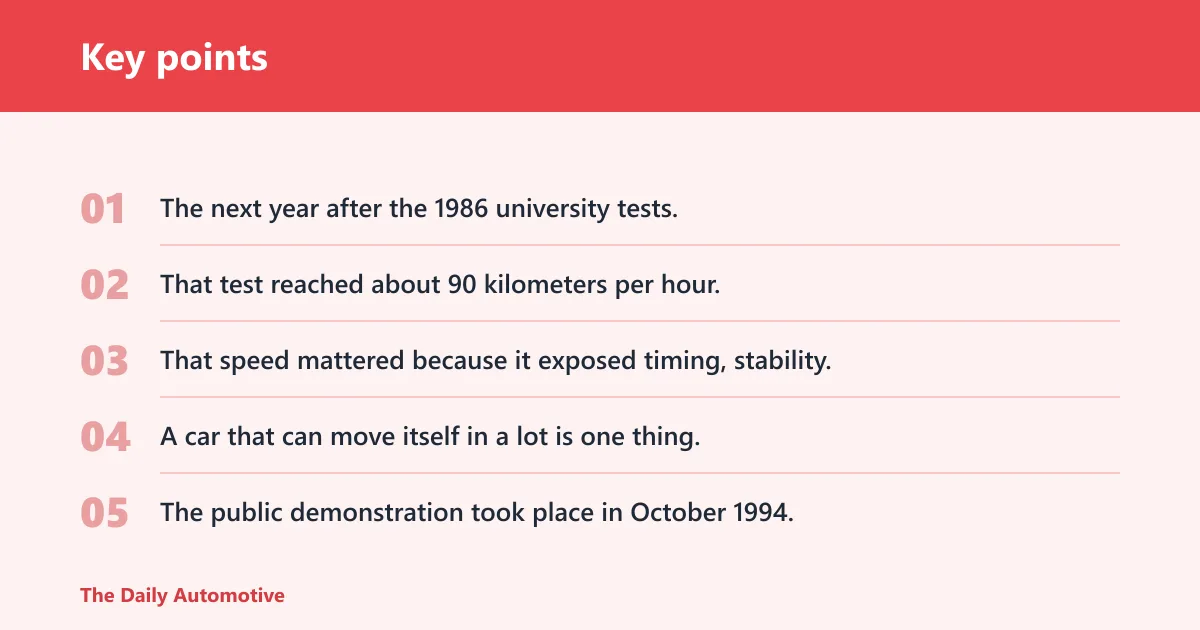
The next year after the 1986 university tests, Dickmanns took the vehicle onto an empty section of Bavarian autobahn. That test reached about 90 kilometers per hour, which made it a major step beyond a closed-course demo.
That speed mattered because it exposed timing, stability, and sensing problems that a skidpan could hide. A car that can move itself in a lot is one thing; a car that can keep pace on a motorway is something else entirely.
First public motorway demo: France in 1994
The public demonstration took place in October 1994. It used two gray Mercedes 500 SELs that drove on France’s Autoroute 1, and they operated autonomously at up to 130 kilometers per hour.
Engineers still sat in the driver’s seat during the demo. That detail matters because it shows how cautious the technology still was, even while it was being shown to the public as a working motorway system.
First long-distance drive: Bavaria to Denmark
The same research line later produced a drive from Bavaria to Denmark that covered more than 1,700 kilometers. That trip exceeded 175 kilometers per hour and demonstrated endurance, not just a short burst of automated control.
Say your prototype can hold lane position for 10 minutes on a test route. That is useful. Suppose the same prototype then has to keep working for hundreds of kilometers, through changing road geometry and traffic conditions. The engineering problem changes from “can it move?” to “can it survive real travel?”
Was Ernst Dickmanns the first person to invent a self-driving car?
No. Dickmanns was an early pioneer, but not the sole inventor of a self-driving car. The better way to read the history is to see him as a major integrator: someone who combined earlier control theory, machine vision, and vehicle engineering into a test program that could be demonstrated on roads.
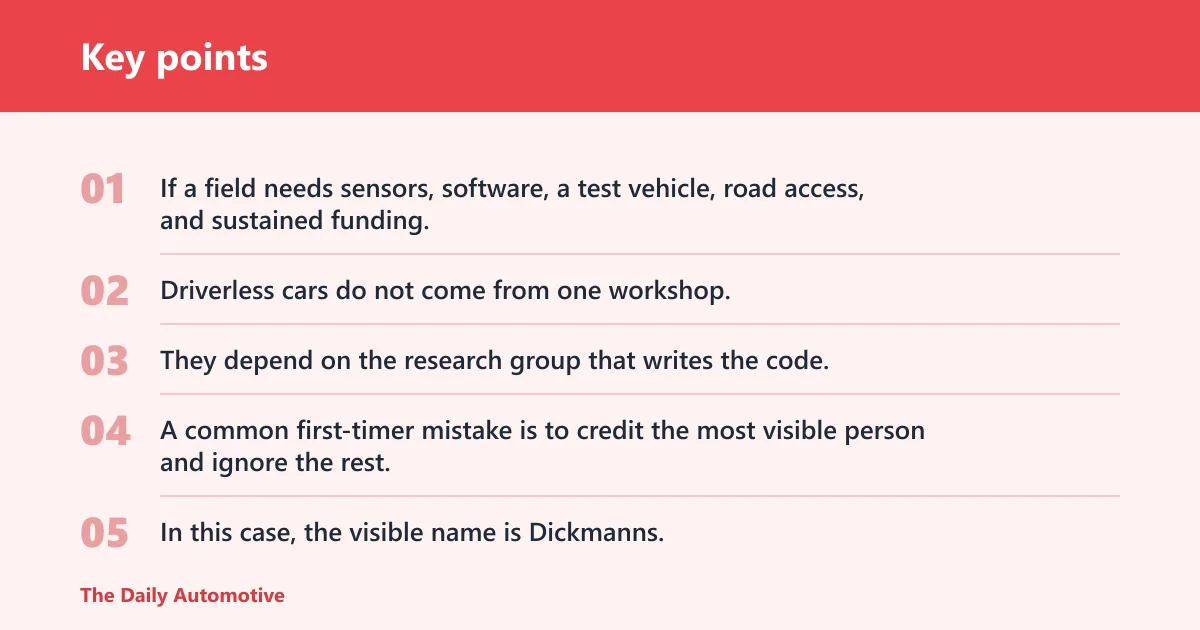
That distinction matters for historians. If a field needs sensors, software, a test vehicle, road access, and sustained funding, then invention is distributed across the people and institutions that contributed each piece.
Why credit should be shared across teams and funders
Driverless cars do not come from one workshop. They depend on the research group that writes the code, the institution that provides test space, the industrial partner that supplies vehicles or money, and the program that allows public trials.
A common first-timer mistake is to credit the most visible person and ignore the rest. In this case, the visible name is Dickmanns, but the project also depended on university teams, Daimler support, and later the massive pan-European PROMETHEUS effort.
How historians should count invention here
For a technology like this, count milestones, not myths. First lab test, first road test, first public motorway demo, and first long-distance drive are separate claims, and each one deserves separate credit.
That approach avoids saying one person invented “the car” or “the system.” It also explains why the answer changes depending on whether you mean proof in a lab, proof on a road, or proof in public traffic.
What was PROMETHEUS?
PROMETHEUS was a massive pan-European effort that helped make the 1994 demonstration possible. It brought together multiple autonomous vehicles and supported work that could not have been done as a small university experiment alone.
Its importance was practical. It gave the project scale, visibility, and funding, and it connected research groups that were pushing vehicle automation in parallel.
How the Mercedes 500 SEL cars reached 130 kilometers per hour
They drove autonomously at up to 130 kilometers per hour, with engineers in the front seat to monitor the run and keep the demonstration within a safety envelope.
That combination made the event different from a lab trial. It was public, fast, and politically meaningful, because it showed that autonomous control had moved onto ordinary motorway traffic rather than remaining inside research grounds.
Why early self-driving research slowed
Early self-driving research slowed because the technology hit its limits. Sensors were not yet good enough, computing power was tight, and the systems still depended heavily on road markings, controlled conditions, and human oversight.
The funding picture changed too. Daimler eventually lost interest in further basic research funding, and the broader research direction faded as corporate priorities shifted.
Technical limits in sensors and computing
The early systems were fragile because they had to do several hard things at once: see the road, understand the scene, and control the vehicle in real time. When any part of that chain lagged, reliability suffered.
That is why the 1987 empty autobahn test and the 1994 motorway demo matter so much. They were not proof of a finished product; they were proof that the approach could work under some conditions, while also revealing how much remained unsolved.
Funding shifts and fading public attention
When research funding cools, long-horizon work often disappears from public view. That happened here. The later history was not a clean failure so much as a loss of momentum after the technology plateaued and commercial support moved elsewhere.
The work was later forgotten in part because newer names took over the public story. Google, Tesla, and Uber arrived much later, but they entered an older field that had already been building test vehicles, trial routes, and automated control systems for decades.
Frequently asked questions
Who invented driverless cars?
No single inventor gets the credit. Driverless cars came from layered work in robotics, control systems, machine vision, university research, and industrial funding. Ernst Dickmanns is one of the most important early names, but the milestones belong to teams and institutions as much as to individuals.
What year was the first driverless car invented?
There is no single year that cleanly answers that question. If you mean the first major university testbed in this story, 1986 is the key milestone. If you mean the first public motorway demonstration, that came in October 1994. Different milestones mark different “firsts.”
What did Ernst Dickmanns build in 1986?
He and his university team built a Mercedes van fitted with computers, cameras, and sensors. It was used in university tests and is associated with an early autonomous vehicle on a skidpan. That made it one of the field’s first visible road-vehicle research platforms.
Were there driverless cars before Google and Tesla?
Yes. Decades before Google, Tesla, or Uber, researchers were already running autonomous vehicle tests, road trials, and public demos. Dickmanns’ 1986 work, the 1987 Bavarian autobahn test, and the 1994 French motorway demonstration all predate the modern commercial era by a wide margin.
How did the first self-driving car work?
It used onboard computers, cameras, and sensors to perceive the vehicle’s surroundings and steer accordingly. The system depended on road markings and controlled conditions, then translated what the cameras saw into steering commands. That basic loop was powerful, but still limited by the hardware of the time.
What was the PROMETHEUS project?
PROMETHEUS was a massive pan-European research effort that helped fund and coordinate the 1994 public demonstration. It brought multiple autonomous vehicles into a shared program and gave the work the scale needed for motorway testing in France.
Why did early self-driving car research stop?
The research slowed because the technology hit its limits and funding shifted. Sensor quality, computing power, and dependence on road markings made progress hard, while Daimler eventually lost interest in further basic research funding. The field did not vanish; it simply moved into a quieter phase.
Products related to this article
Sponsored / affiliate links. As an Amazon Associate I earn from qualifying purchases. I may earn additional commission from eligible campaigns.
 FH Group Car Seat Cover Front Set Striking Striped Car Seat Covers with Front Seat Covers and Rear Split Bench, Universal Fit Interior Accessories for Cars, Trucks, and SUVs – Gray
 4G GPS Tracker Car Anti-Theft Long Battery Life 20000mAh Real Time GPS Tracking Device Magnet No Geographic Restriction Car Tracker with Alerts, Geo Fence, History Playback TK905C